Let’s discuss your project ↗
G series

AGIBOT G2 Packaging Solution

A G2 integration package combining the robot body, VR equipment, controller, OmniPicker and transport case.

Contact us for pricing.

Availability and configuration are agreed individually.

185 kgplatform weight
25DoF, excluding end effectors
5 kg/armrated payload
IP42protection rating
MEET THE PLATFORM

A closer look at the AGIBOT G2 integration package.

AGIBOT G2 Packaging Solution — Two robot arms on a wheeled chassis.
Application images show G2 with end effectors; the Body version is supplied without end effectors.

Two robot arms on a wheeled chassis.

With its wheeled chassis and two arms, G2 supports industrial object-handling tasks. Planning must consider the gripper, workpiece and robot workspace together.
AGIBOT G2 Packaging Solution — Coordinated gripping and movement.

Coordinated gripping and movement.

Force-controlled manipulation and the Genie RL ecosystem support training and integration workflows. Industrial tasks also require defined object variations and cycle acceptance criteria.

Choose a platform or an integration package.

The G2 Packaging Solution includes the robot, VR equipment, controller, OmniPicker gripper and transport case. The Body version is supplied without end effectors; its accessories are selected separately.

AGIBOT G2 Packaging Solution – AGIBOT G2 during an object-handling pilot — application illustration

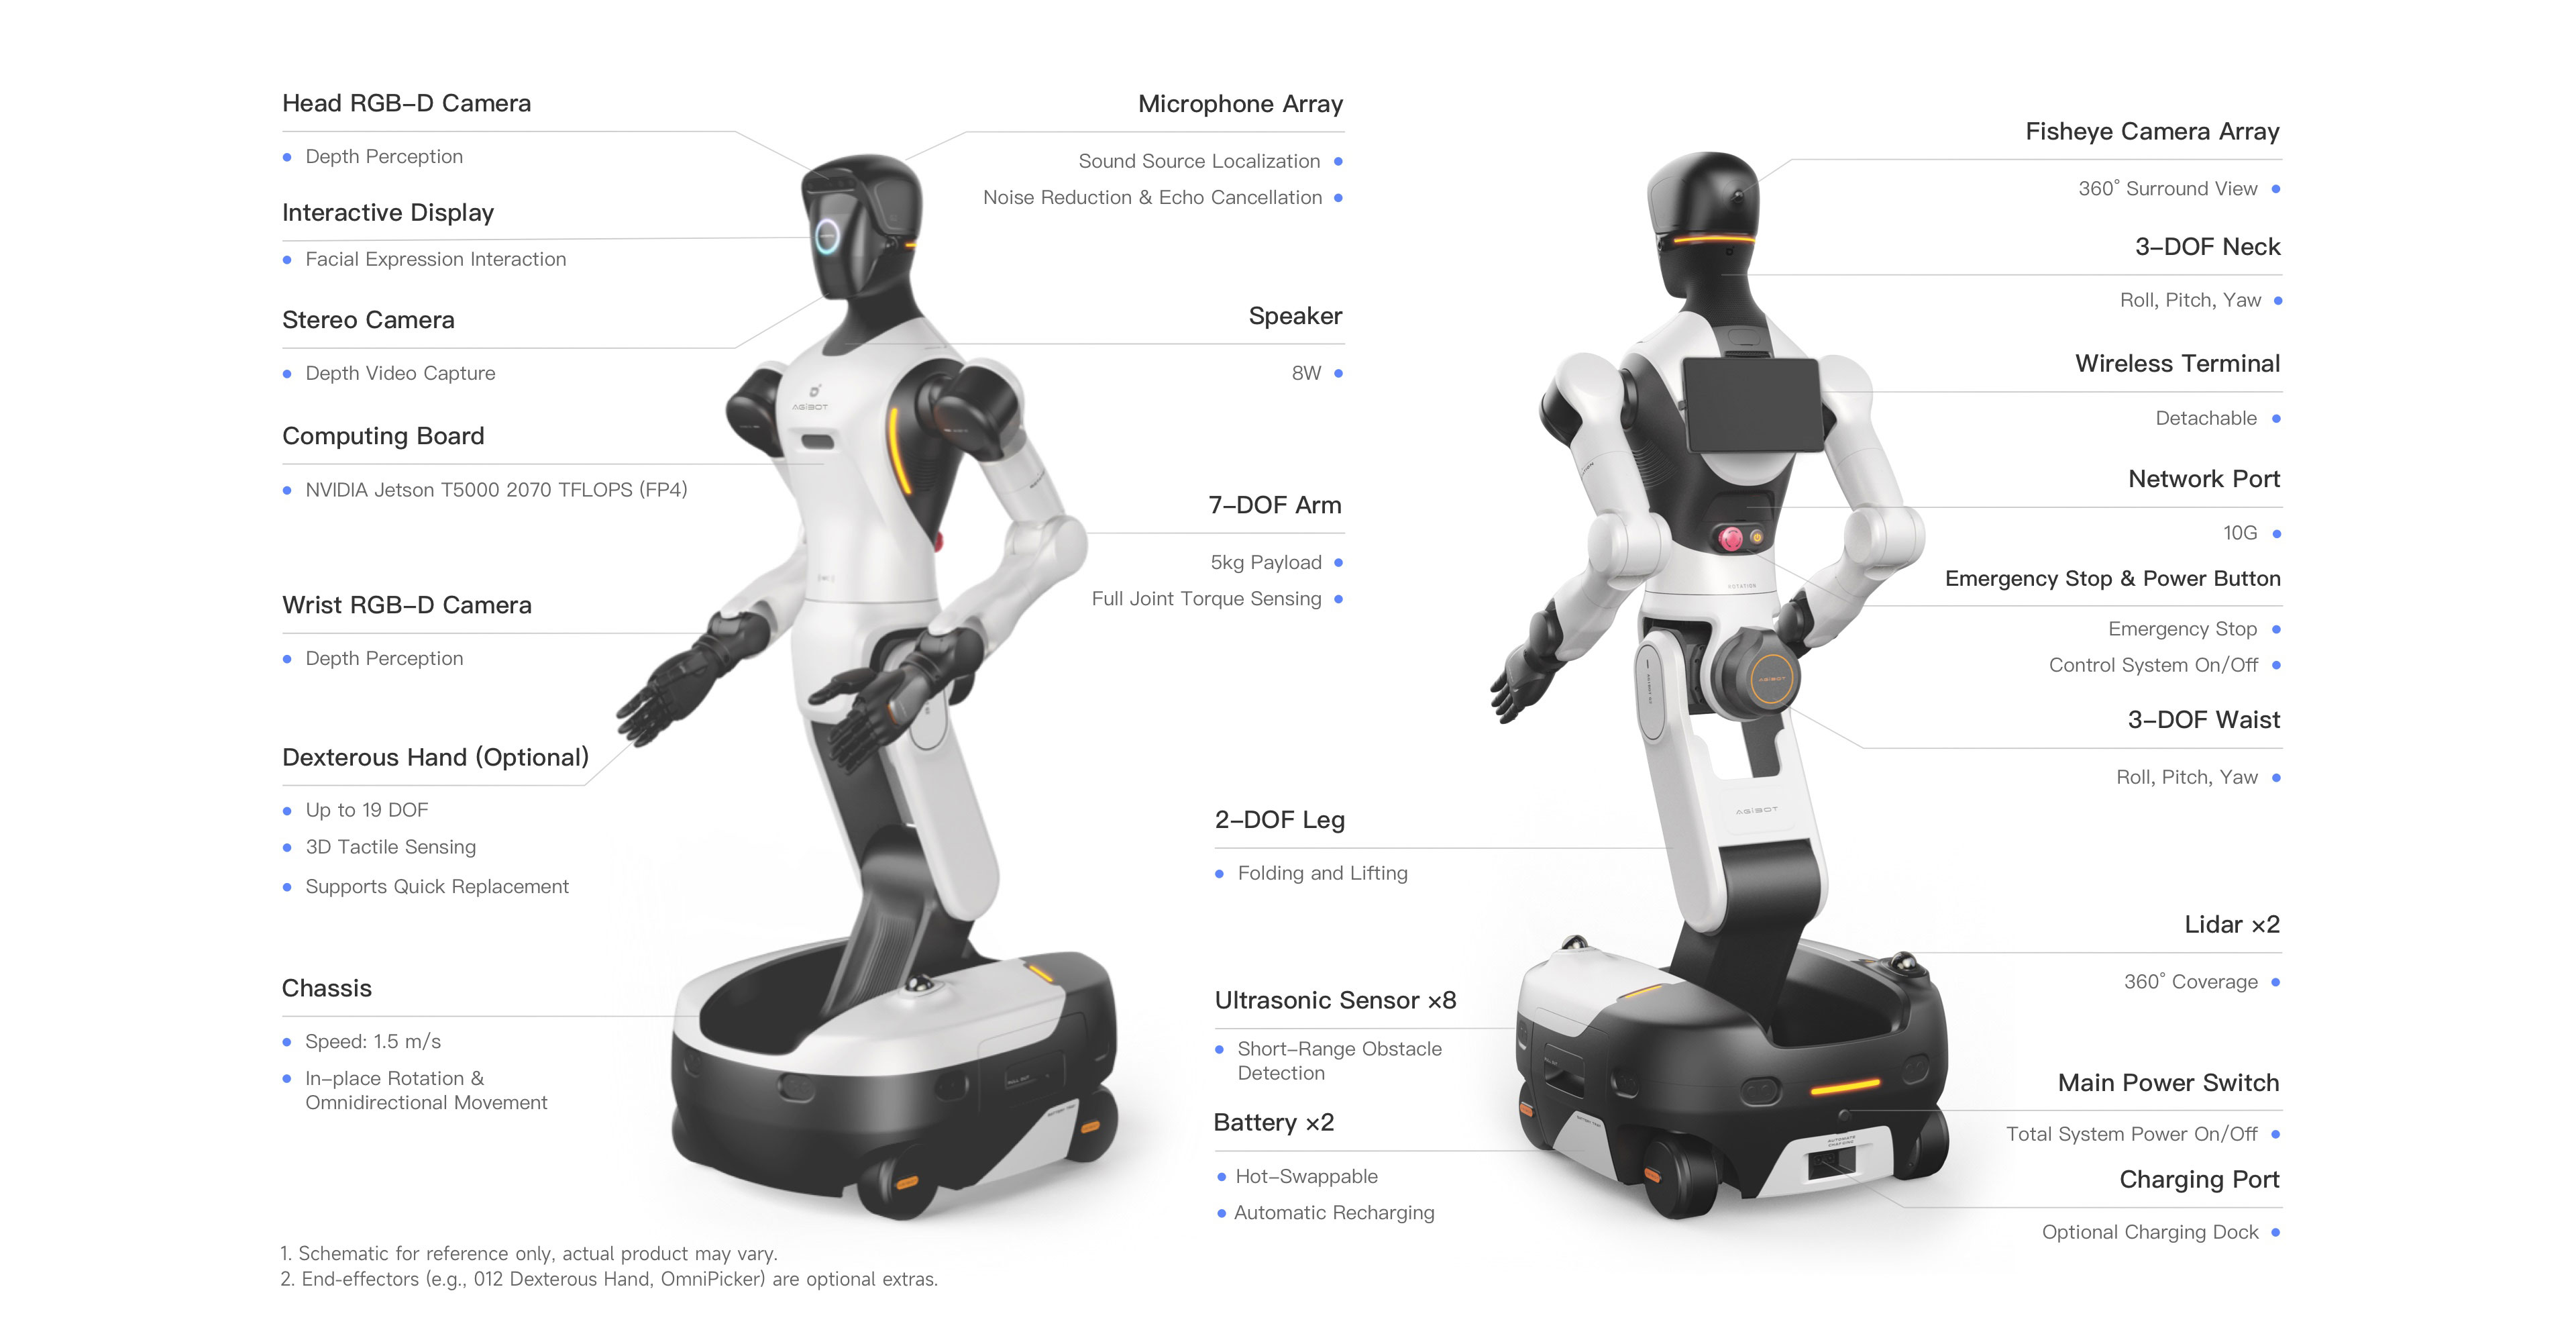
The platform, explained.

Front view

  1. Head cameras

    Head-mounted RGB-D and stereo cameras capture visual and depth information.

  2. Interactive display

    Animated facial expressions make the robot’s responses visible.

  3. Microphone array and speaker

    Sound-source localisation, noise reduction and echo cancellation, with an 8 W speaker.

  4. Onboard computing

    Available with an NVIDIA Jetson T5000 controller delivering 2070 TFLOPS at FP4 precision.

  5. Force-sensing arms

    Seven degrees of freedom per arm, a 5 kg payload and joint torque sensing.

  6. Wrist RGB-D cameras

    Close-range colour and depth sensing around the grasping area.

  7. Interchangeable dexterous hand

    Optional hand with up to 19 DoF, 3D tactile sensing and quick replacement.

  8. Omnidirectional chassis

    In-place rotation, sideways motion and a travel speed of up to 1.5 m/s.

Rear view

  1. Surround-view cameras

    A fisheye camera array provides 360° visual coverage.

  2. Articulated neck

    Three neck DoF enable yaw, pitch and roll.

  3. Detachable wireless terminal

    A rear-mounted wireless terminal and a 10G wired network connection.

  4. Emergency stop and control

    Rear-mounted emergency-stop and control-system power buttons.

  5. Waist and lifting mechanism

    Three waist DoF and a two-DoF folding and lifting section adjust body position and working height.

  6. LiDAR and ultrasonic sensing

    Two LiDAR units provide 360° coverage, with eight ultrasonic sensors for nearby obstacles.

  7. Dual hot-swappable batteries

    Two batteries support hot swapping. An optional charging station enables automatic recharging.

  8. Main power and charging

    The chassis houses the main system power switch and charging connection.

Equipment overview

Movement and mechanics

Active degrees of freedom, excluding end effectors
25
Neck degrees of freedom
3
Waist and leg assembly degrees of freedom
5

Sensing and control

3D LiDAR
2 units
Stereo camera
1 unit
Fisheye camera
3 units

Power and operation

Ingress protection
IP42 according to the manufacturer’s product presentation
Number of batteries
2 units
Operating time
approx. 4 hours
COMPLETE DATA SHEET

Technical specifications.

Manufacturer specifications and measurement conditions, organised by topic.

Source: AGIBOT ↗

General specifications — manufacturer table

Height
1225–1795 mm
Width
640 mm
Length
760 mm
Weight
185 kg, platform reference
Active degrees of freedom, excluding end effectors
25
Neck degrees of freedom
3
View full technical specificationsShow less
Degrees of freedom per arm
7
Waist and leg assembly degrees of freedom
5
Mobile base degrees of freedom
3

The complete current AGIBOT product table, supplemented with detailed specifications from the G2 manual. Standard and high-performance computers are separate variants, not equipment installed together. O10 workspace figures are references measured with an optional robotic hand. The supplied EU configuration is confirmed separately.

Sensors and interaction — manufacturer table

3D LiDAR
2 units
Stereo camera
1 unit
Fisheye camera
3 units
Head RGB-D camera
1 unit
Wrist RGB-D cameras
2 units
Microphone array
Equipped
Speaker
Equipped
Interactive display
Equipped
Multicolour LED strip
Equipped

Performance — manufacturer table

Rated arm payload
5 kg/arm
Joint torque sensors
Equipped
Mobile base speed
1.5 m/s
Motion modes
Omnidirectional movement, sideways travel and rotation on the spot
Ingress protection
IP42 according to the manufacturer’s product presentation

Battery and charging — manufacturer table

Number of batteries
2 units
Total battery capacity
1652 Wh
Operating time
approx. 4 hours
Power supply
Direct charging, battery replacement; automatic return to an optional charging station
Charging time
≤ 2.5 hours
Charger input
100–240 V
Charger output
54.75 V / 15 A

Computing and control — manufacturer table

High-performance version
NVIDIA Jetson T5000, 2070 TFLOPS (FP4); not standard in every Body / Packaging configuration
Communication
Wi-Fi, Bluetooth; optional 4G/5G
Wireless handheld terminal
Available
OTA updates
Available
Secondary development
Supported

Workspace and environment — manual supplement

Vertical workspace with O10 hands
0–2.3 m; O10 is not included in the Body package
Arm span with O10 hands
2.3 m
Operating temperature
Manual specification table: 0…45 °C; safety section: 0…40 °C. Confirm for the delivered version
Storage temperature
−20…60 °C
Operating humidity
≤ 90% in the specification table; the safety section requires a value below 90%
Operating environment
Indoor, level ground; the safety section permits a maximum gradient of 5%

Joint movement ranges — manual

Head yaw
±70°
Head roll
±20°
Head pitch
±27°
Waist yaw
±174°
Waist lateral tilt
±24°
Waist bending
−104°…58°
Knee range of motion
0°…151°
Ankle range of motion
−61°…0°
Shoulder rotation
±178°
Shoulder elevation
±120°
Upper arm rotation
±178°
Elbow range of motion
−145°…60°
Forearm rotation
±178°
Wrist elevation
±90°
Wrist lateral movement
±60°

Detailed camera specifications — manual

Head stereo camera resolution
Both image sensors: 1920 × 1536 px
Head stereo camera frame rate
60 fps
Head stereo camera field of view
118° horizontal × 92° vertical
Fisheye camera resolution
1920 × 1537 px according to the manual table
Fisheye camera frame rate
30 fps
Fisheye camera field of view
215° horizontal × 170° vertical
Head RGB-D colour image resolution
1280 × 800 px
Head RGB-D colour image frame rate
60 fps
Head RGB-D colour image field of view
94° horizontal × 68° vertical
Head RGB-D depth image resolution
1280 × 800 px
Head RGB-D depth image frame rate
30 fps
Head RGB-D depth image field of view
90° horizontal × 65° vertical
Wrist RGB-D colour image resolution
1920 × 1080 px
Wrist RGB-D colour image frame rate
25 fps
Wrist RGB-D colour image field of view
105° horizontal × 85° vertical
Wrist RGB-D depth image resolution
640 × 480 px
Wrist RGB-D depth image frame rate
25 fps
Wrist RGB-D depth image field of view
90° horizontal × 70° vertical

Distance sensing and IMU — manual

LiDAR minimum measuring distance
0.1 m
LiDAR range accuracy (1σ)
≤ 2 cm at a distance of 10 m; ≤ 3 cm at a distance of 0.2 m
LiDAR field of view
360° horizontal; −7°…52° vertical
LiDAR point rate
200 000 points/s
LiDAR update rate
10 Hz
Number of ultrasonic sensors
8 units
Ultrasonic measuring accuracy
20 mm
Ultrasonic measuring range
The manual states 30–3000 m; the unit appears incorrect and requires confirmation
Ultrasonic sensing angle
100° ±10° horizontal; 60° ±10° vertical
Gyroscope bias over the full temperature range
Typically 0.015 °/s; maximum 0.03 °/s
Gyroscope measuring range
±250 °/s
Gyroscope bias stability
Typically 4 °/h; maximum 6 °/h
Accelerometer range
±8 g
Accelerometer bias over the full temperature range
Typically 1.5 mg; maximum 2 mg
Accelerometer bias stability
Typically 0.07 mg; maximum 0.1 mg

Audio and display — manual

Number of microphones
4-microphone array
Microphone sensitivity
−32 ±3.5 dB
Microphone signal-to-noise ratio
70 dBA
Number of speakers
1 unit
Speaker rated power
8 W
Speaker maximum power
10 W
Speaker impedance
4 Ω ±15%
Speaker resonance frequency
200 Hz ±20%
Speaker sensitivity
83 ±3 dB
Speaker frequency range
f₀–8 kHz, where f₀ is the resonance frequency
Interactive display dimensions
6.3 inches
Interactive display brightness
500 nits

Manipulation and navigation — manual

Combined rated payload of both arms
10 kg
Combined peak payload of both arms
15 kg; not a continuous rated payload
Arm length
696 mm
Arm repeatability
±0.1 mm
Arm absolute positioning accuracy
±1 mm
Force-control torque resolution
≤ 0.02 Nm
Force sensor sampling rate
≥ 5 kHz
Torso design
5-DoF folding lift system
Waist functions
Pitch, yaw and roll
Leg assembly function
Folding lift and lowering mechanism
Mobile base design
4 steered wheels
Turning on the spot
Supported
Sideways movement
Supported
Standard navigation accuracy
±5 cm, ±3°
High-precision navigation
±3 cm, ±2°
Obstacle clearance
1.5 cm
Slope capability in the specification table
≤ 5°; observe the stricter 5% limit in the manual safety section
Minimum navigation passage width
850 mm

Computer variants — manual

Standard version computing performance
500 TOPS (INT8)
Standard version CPU
24 × A78 cores
Standard version memory
64 GB
Standard version storage
2 TB NVMe SSD
High-performance version computing performance
2070 TFLOPS (FP4); not directly comparable with INT8 TOPS
High-performance version CPU
14 × Poseidon-AE cores
High-performance version memory
128 GB
High-performance version storage
2 TB NVMe SSD

Connectors — manual

Internet Ethernet port
1 Gbps
First local Ethernet port
1 Gbps
Second local Ethernet port
10 Gbps
USB Type-A
USB 3.0 speed, only on the standard / lower-compute version
USB Type-C
USB 3.0 speed
SIM slot
4G/5G support; cellular module optional
DisplayPort
Standard version, controller display output
Service port
Upper-body debugging, for qualified service personnel only. The high-performance version also lists a serial debug port
End-effector connector
M8, 8-pin
End-effector power supply
1 × 24 V
End-effector communication
2 × RS485 and 1 × CAN-FD
Connecting the end effector
Only when powered off; end-effector hot swapping is not supported

Electrical specifications and operator terminal — manual

Total battery capacity in Ah
34 Ah
Rated supply voltage
48 V
Rated current
8.3 A
Rated power
approx. 400 W
Charger model
UY900L-W547150
Maximum charger power
821.25 W
Charger input frequency
47–63 Hz
Wireless terminal display
11.5 inches
Wireless terminal resolution
2000 × 1200 px
Physical emergency stop
Supported

Actual performance depends on the environment, load, software and configuration. Maximum values may reflect different test conditions and may not be achievable simultaneously.

DELIVERY & EQUIPMENT

Package contents and options.

Package contents

  • G2 robot platform
  • VR equipment
  • Handheld controller
  • OmniPicker
  • Protective transport case

To be agreed in the quotation

  • End effectors, mechanical adapters and cabling.
  • VR, data-acquisition equipment and licences.
  • Workpieces, cycle time and gripping requirements.
  • Industrial network and target-system interfaces.

The confirmed quotation itemises the equipment and licences included in the delivery. Illustrations may show optional accessories.

Applications.

Examples of possible uses. Required development and services are agreed for each project.

Handling trials · AGIBOT G2 Packaging Solution

Handling trials

Evaluate picking, moving and handling workpieces.

Robotics data collection · AGIBOT G2 Packaging Solution

Robotics data collection

Record demonstrated movement sequences with the appropriate data acquisition equipment.

Industrial integration · AGIBOT G2 Packaging Solution

Industrial integration

Develop system connections and workflows around the site requirements.

BEFORE CHOOSING YOUR CONFIGURATION

Frequently asked questions.

What does Robot Only Body mean?

It refers to the robot platform without end effectors. Grippers, hands, VR devices and data-collection equipment must be listed separately to be included.

Is the Packaging Solution a finished automation system?

The package contains its listed equipment. Workflow design, training, integration and site validation remain project tasks.

Do related models have the same specifications?

Not automatically. Check the exact variant, installed equipment and corresponding specification together.

NT SYS · AGIBOT ROBOTICS

Let’s discuss your application.

We help select the right model, equipment and services.