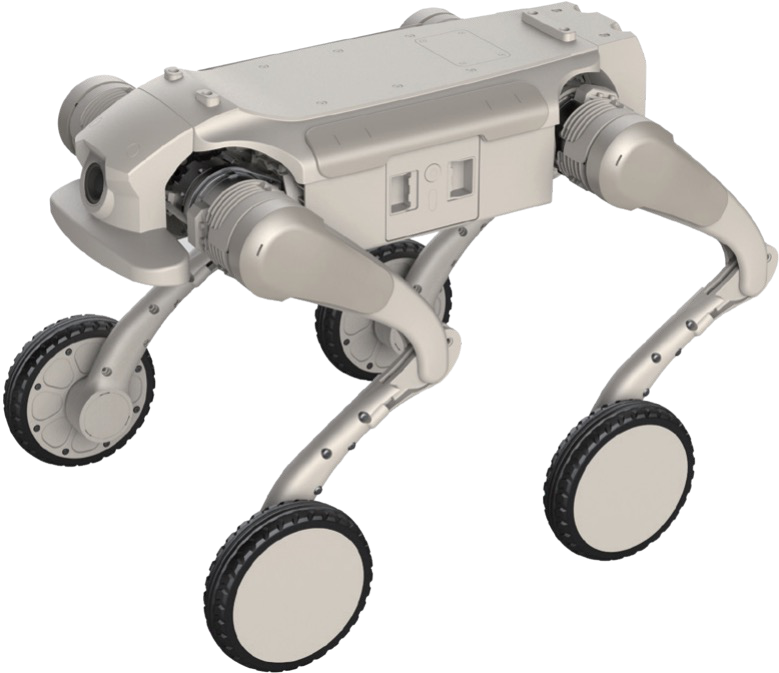
Mobility matched to the site.
Choosing a quadruped means considering stairs, slopes, surfaces and payload. D1 models differ in payload capacity, operating conditions and expansion options.
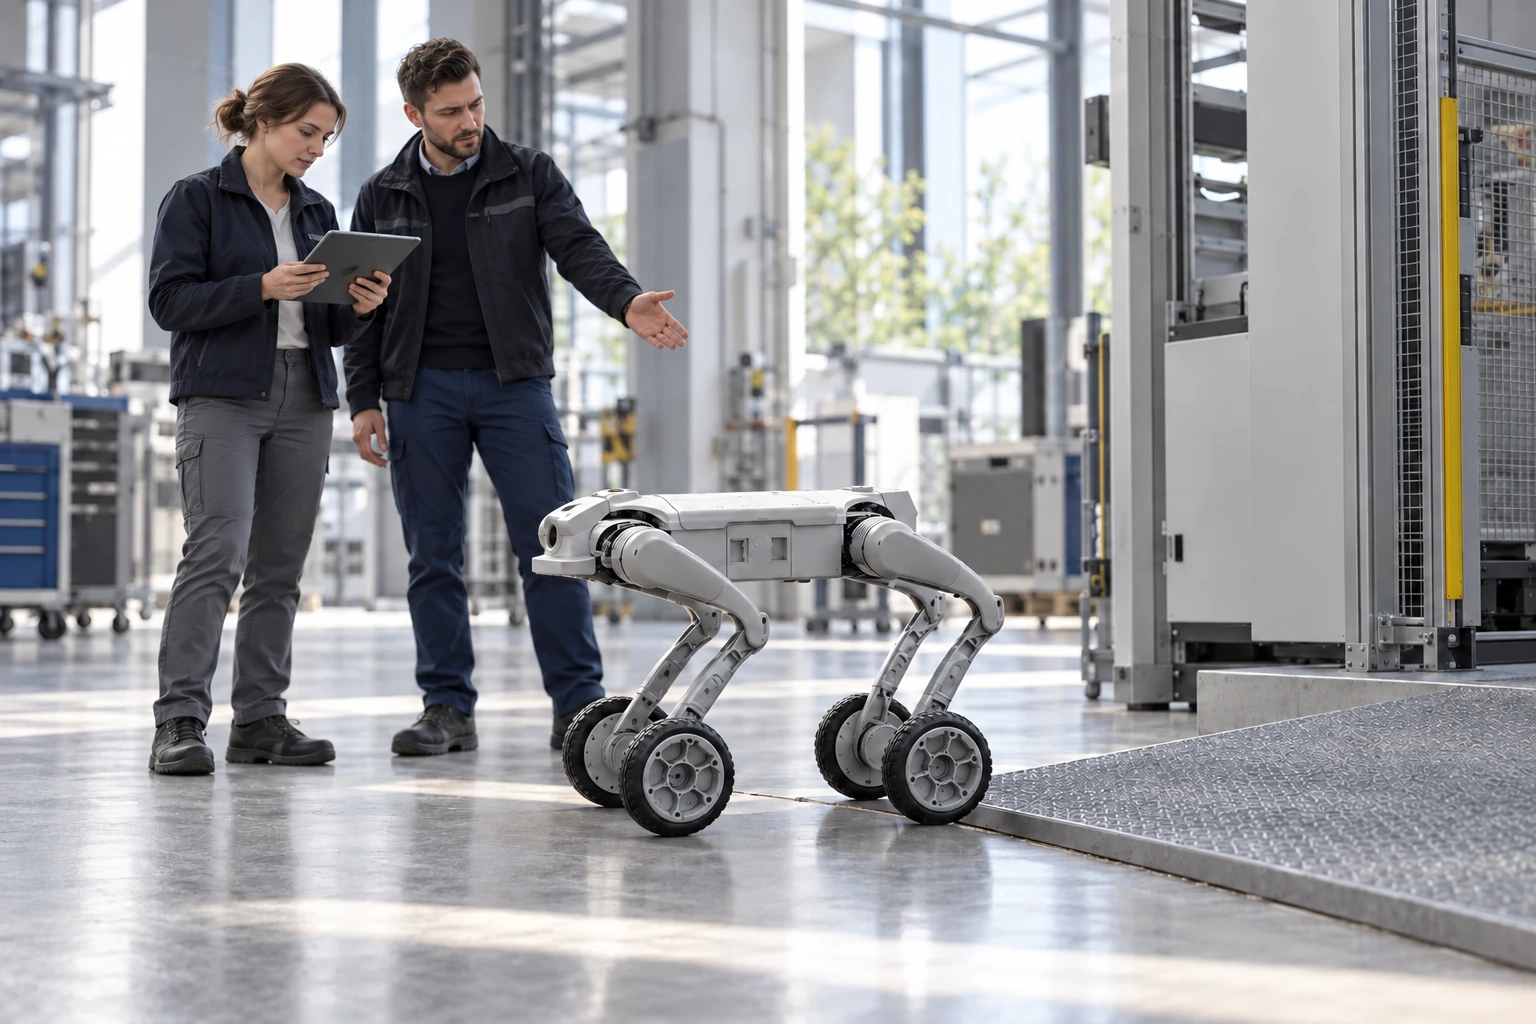
 Robotics
The software and equipment required for these applications are specified in the quotation.
A compact wheel-legged D1 platform for mixed indoor routes and uneven ground.
Contact us for pricing.
Availability and configuration are agreed individually.
Choosing a quadruped means considering stairs, slopes, surfaces and payload. D1 models differ in payload capacity, operating conditions and expansion options.
Developer access and expansion interfaces allow the connection of custom sensors, communication devices and control software. Autonomous operation also requires suitable software and site configuration.
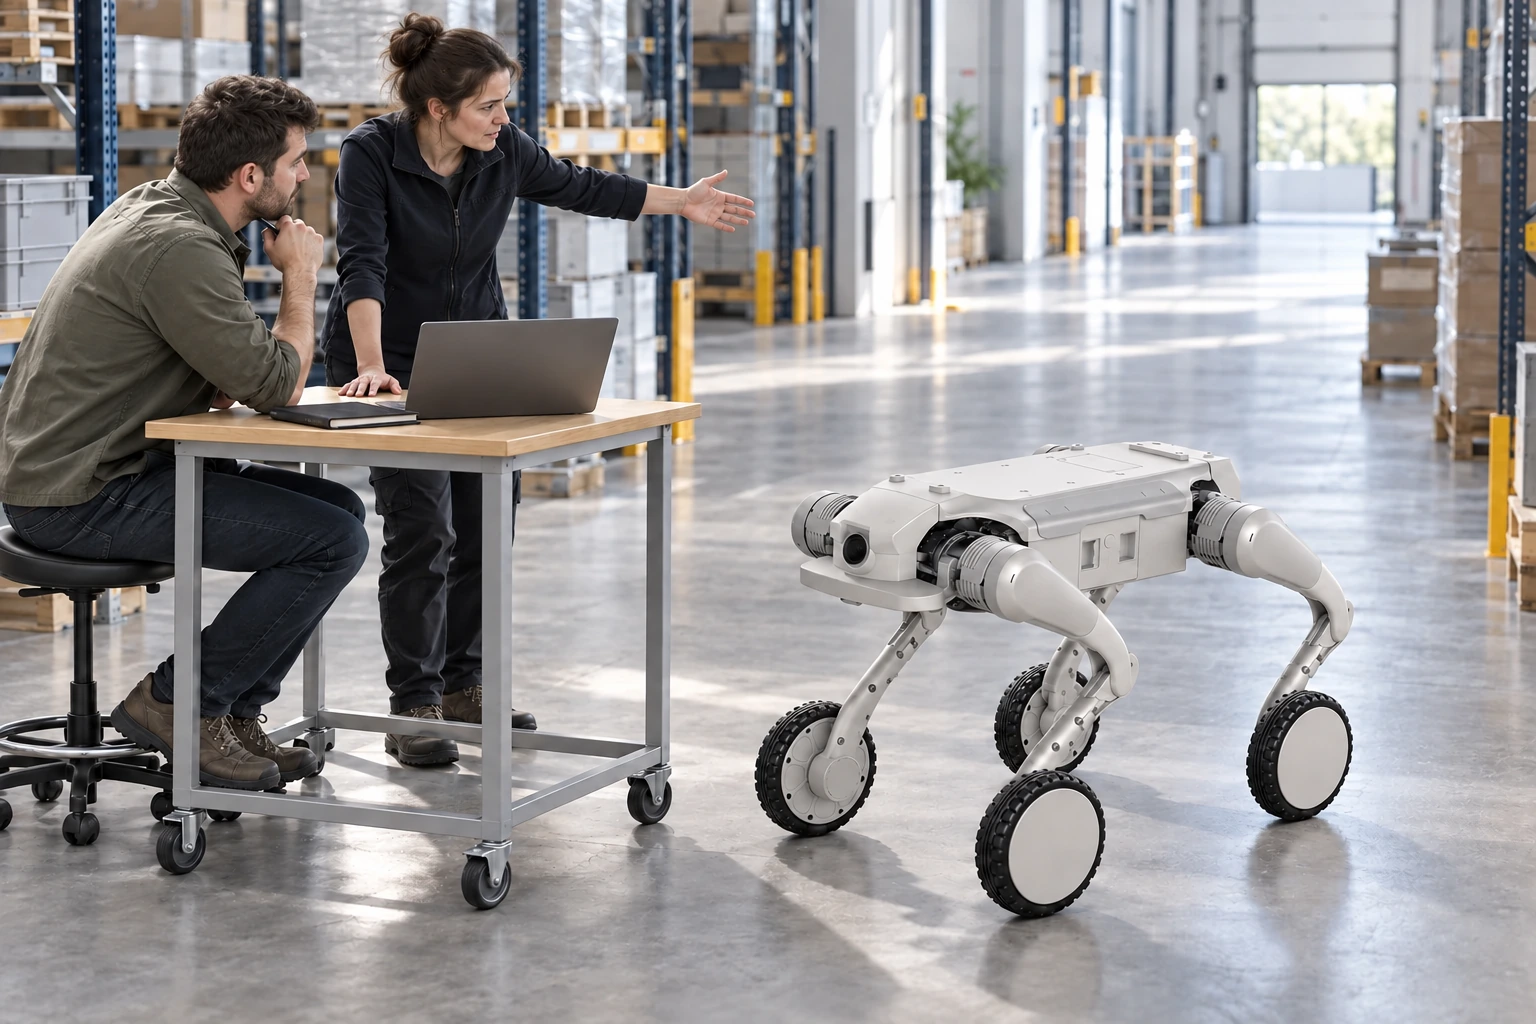
Payload, terrain and speed all affect operating time. Operational planning also covers the charging location, battery changes and the operator’s tasks.
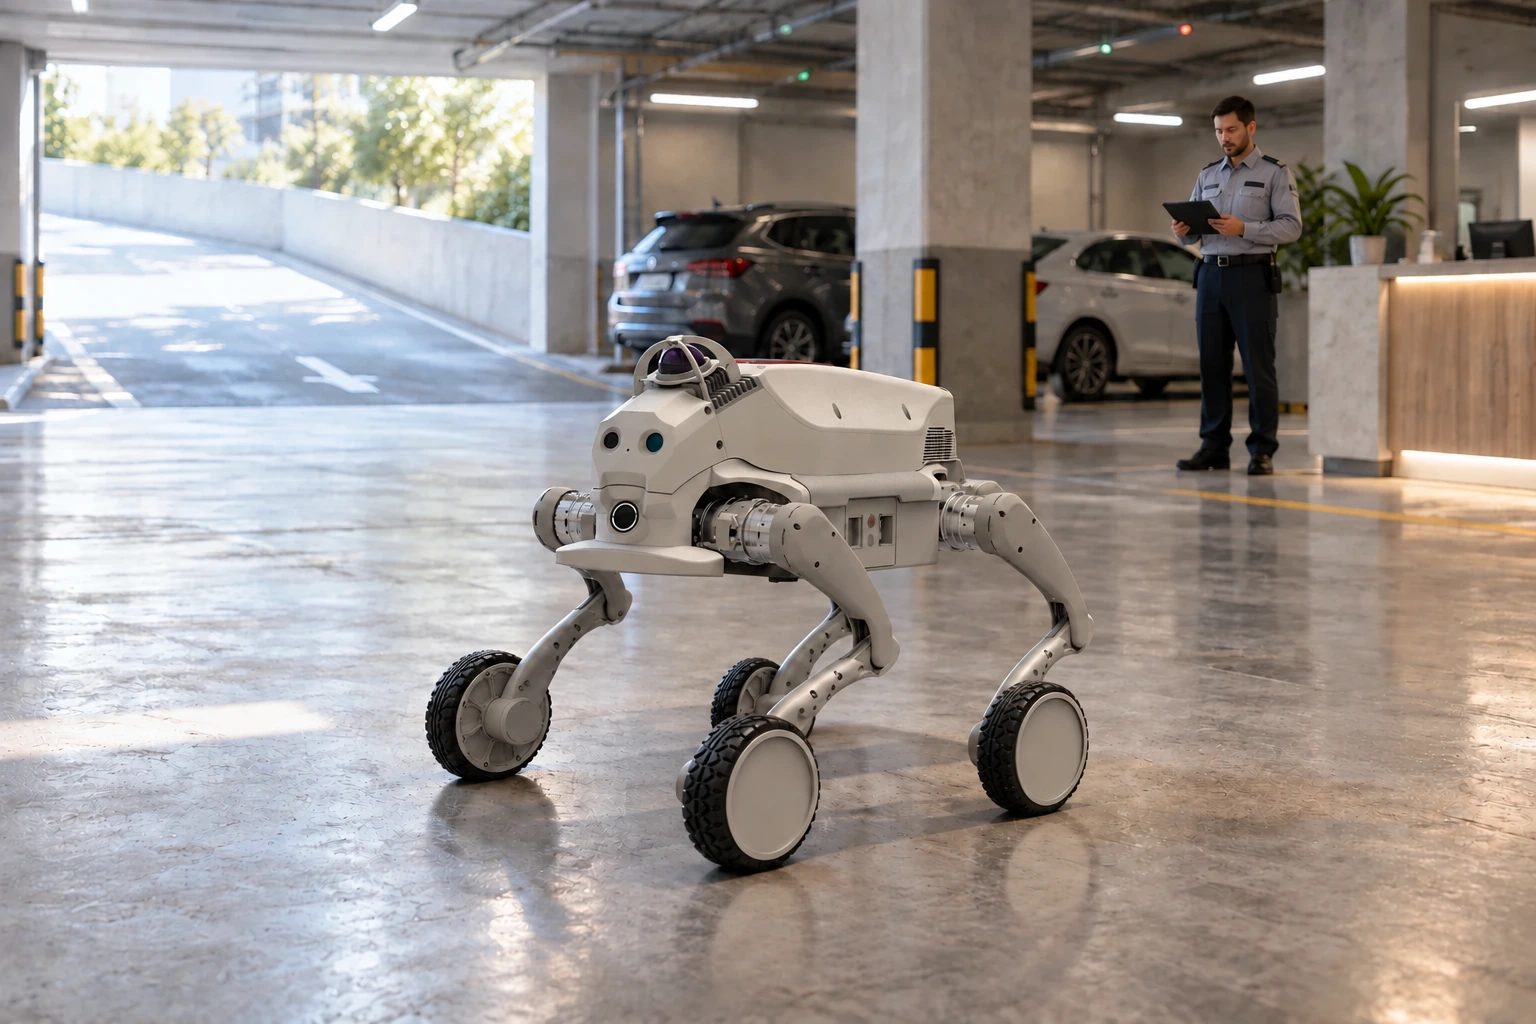
The camera shows the robot’s forward view, while a front guard protects the body.
Protective strips and pads surround the body and joints.
A rear guard is paired with a status light.
The upper interface panel connects external modules.
The battery module is accessible from the side.
Powered joints coordinate the upper and lower leg links.
Hub motors drive six-inch wheels with solid tyres.
Manufacturer specifications and measurement conditions, organised by topic.
Source: AGIBOT ↗
Based on the complete specification table in AGIBOT’s separate 2026 D1 Ultra-W publication. This is the 22 kg wheel-legged version, not the 16 kg D1 Ultra. Published values are laboratory data; the quotation specifies the supplied EU equipment.
Actual performance depends on the environment, load, software and configuration. Maximum values may reflect different test conditions and may not be achievable simultaneously.
The confirmed quotation itemises the equipment and licences included in the delivery. Illustrations may show optional accessories.
Examples of possible uses. Required development and services are agreed for each project.
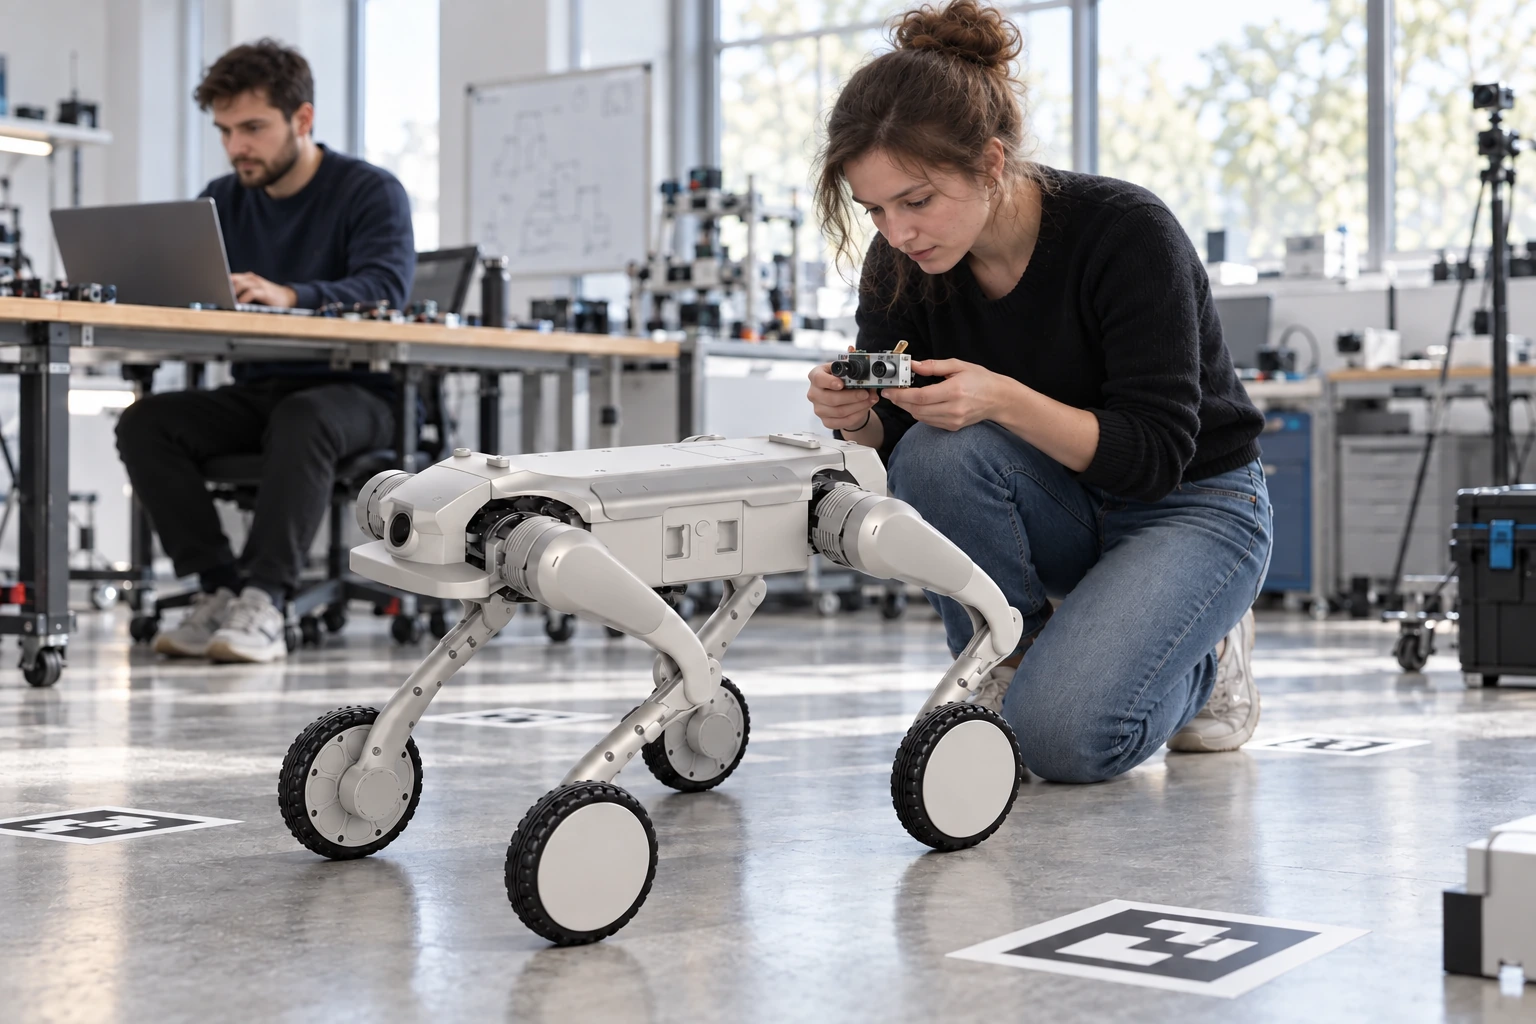
Motion control, sensor integration and experiments with a development-capable configuration.
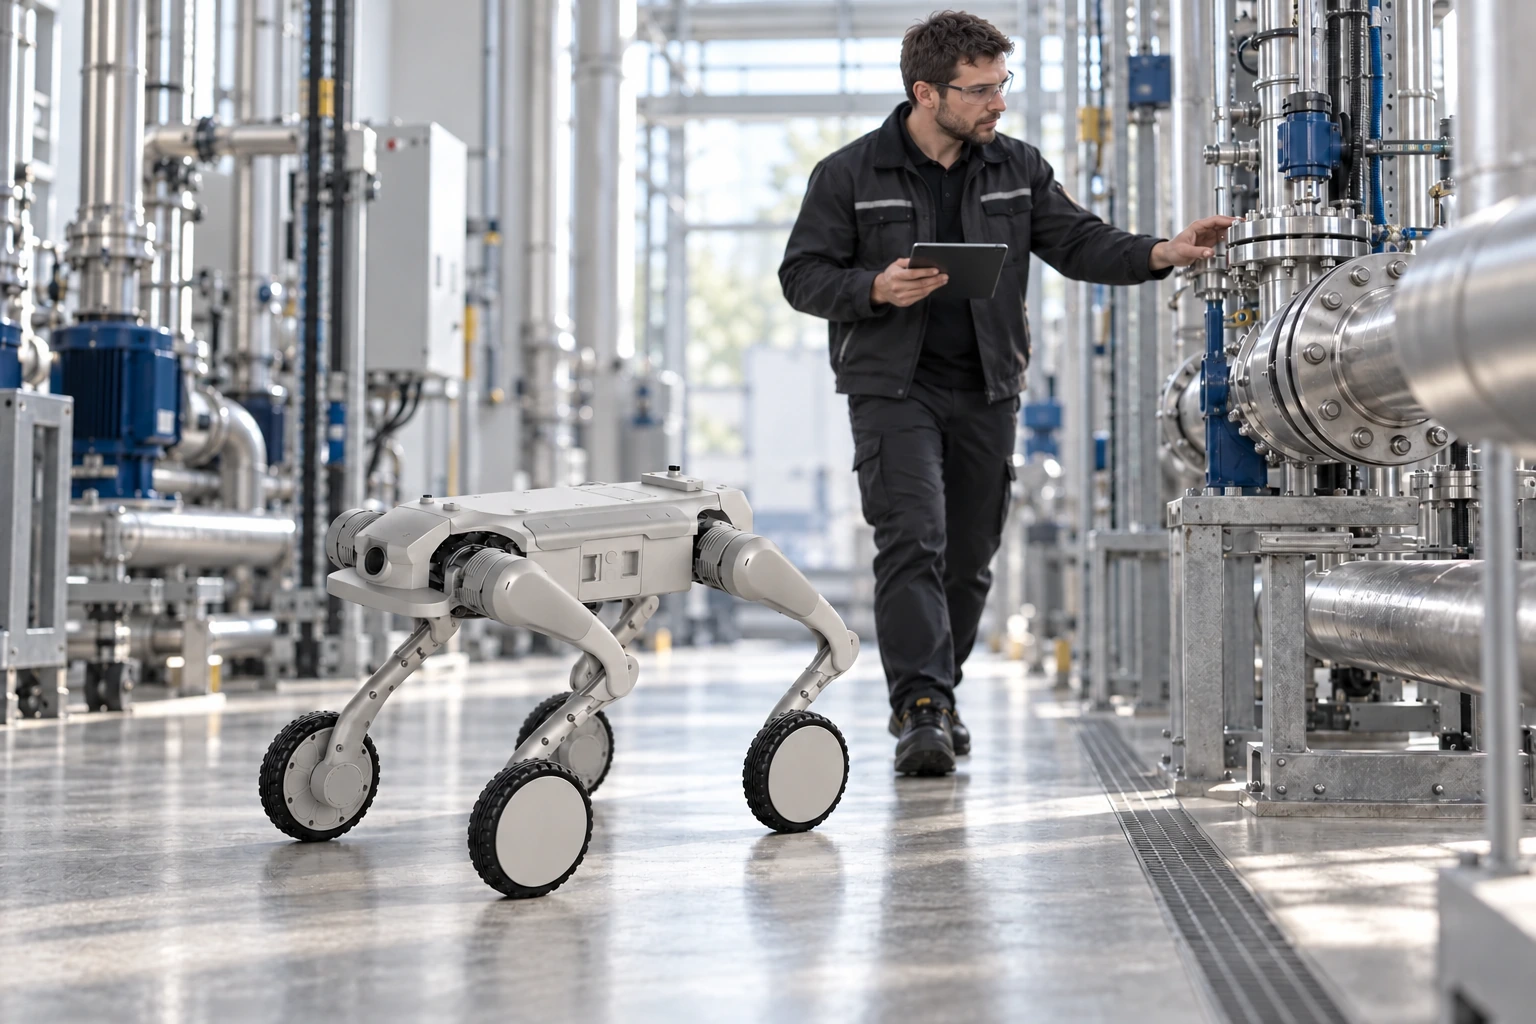
Regular routes and task-specific sensors, with separate integration.

Remote supervision, event handling and a system developed through an on-site pilot.
Sensors and autonomous functions are included only when explicitly listed in the selected configuration.
Payload, speed, terrain, temperature and accessory power consumption all matter. Validate the intended route rather than relying solely on laboratory figures.
Not automatically. Check the exact variant, installed equipment and corresponding specification together.
Product data and manufacturer images: AGIBOT. For custom solution packages, the reference describes the base platform.
We help select the right model, equipment and services.