Gripping matched to the object.
End-effector selection starts with the object’s size, material, weight and required movement. Include the hand or gripper’s own weight when calculating the total arm load.

 Robotics
Manufacturer illustrations may show optional equipment. The quotation defines the supplied configuration.
An adaptive gripper for handling objects with different shapes on a compatible robot platform.
Contact us for pricing.
Availability and configuration are agreed individually.
End-effector selection starts with the object’s size, material, weight and required movement. Include the hand or gripper’s own weight when calculating the total arm load.
Force control helps adapt the grip to the application. Hand control modes are selected for the object and task; tactile feedback is available only on the variant equipped with the relevant sensors.

Successful gripping requires calibration and control settings as well as mechanical integration. Prototyping with the actual objects verifies grip stability and the available range of motion.

The padded contact surface on the wide finger supports the object.
The narrower finger closes against the opposite side of the object.
Driving and driven connecting rods coordinate finger movement.
A torsion spring at the joint assists the mechanism’s return.
The internal transmission transfers motor movement to the fingers.
The motor and its drive are integrated into the lower housing.
A 24 V supply and six-pin interface at the base.
Manufacturer specifications and measurement conditions, organised by topic.
Source: AGIBOT ↗
Public AGIBOT component data for the 0.43 kg OmniPicker, not the newer 600 g OmniPicker 3. The adapter and supplied version require confirmation; 30 N gripping force is not equivalent to robot-arm payload capacity expressed in kg.
Actual performance depends on the environment, load, software and configuration. Maximum values may reflect different test conditions and may not be achievable simultaneously.
The confirmed quotation itemises the equipment and licences included in the delivery. Illustrations may show optional accessories.
Examples of possible uses. Required development and services are agreed for each project.
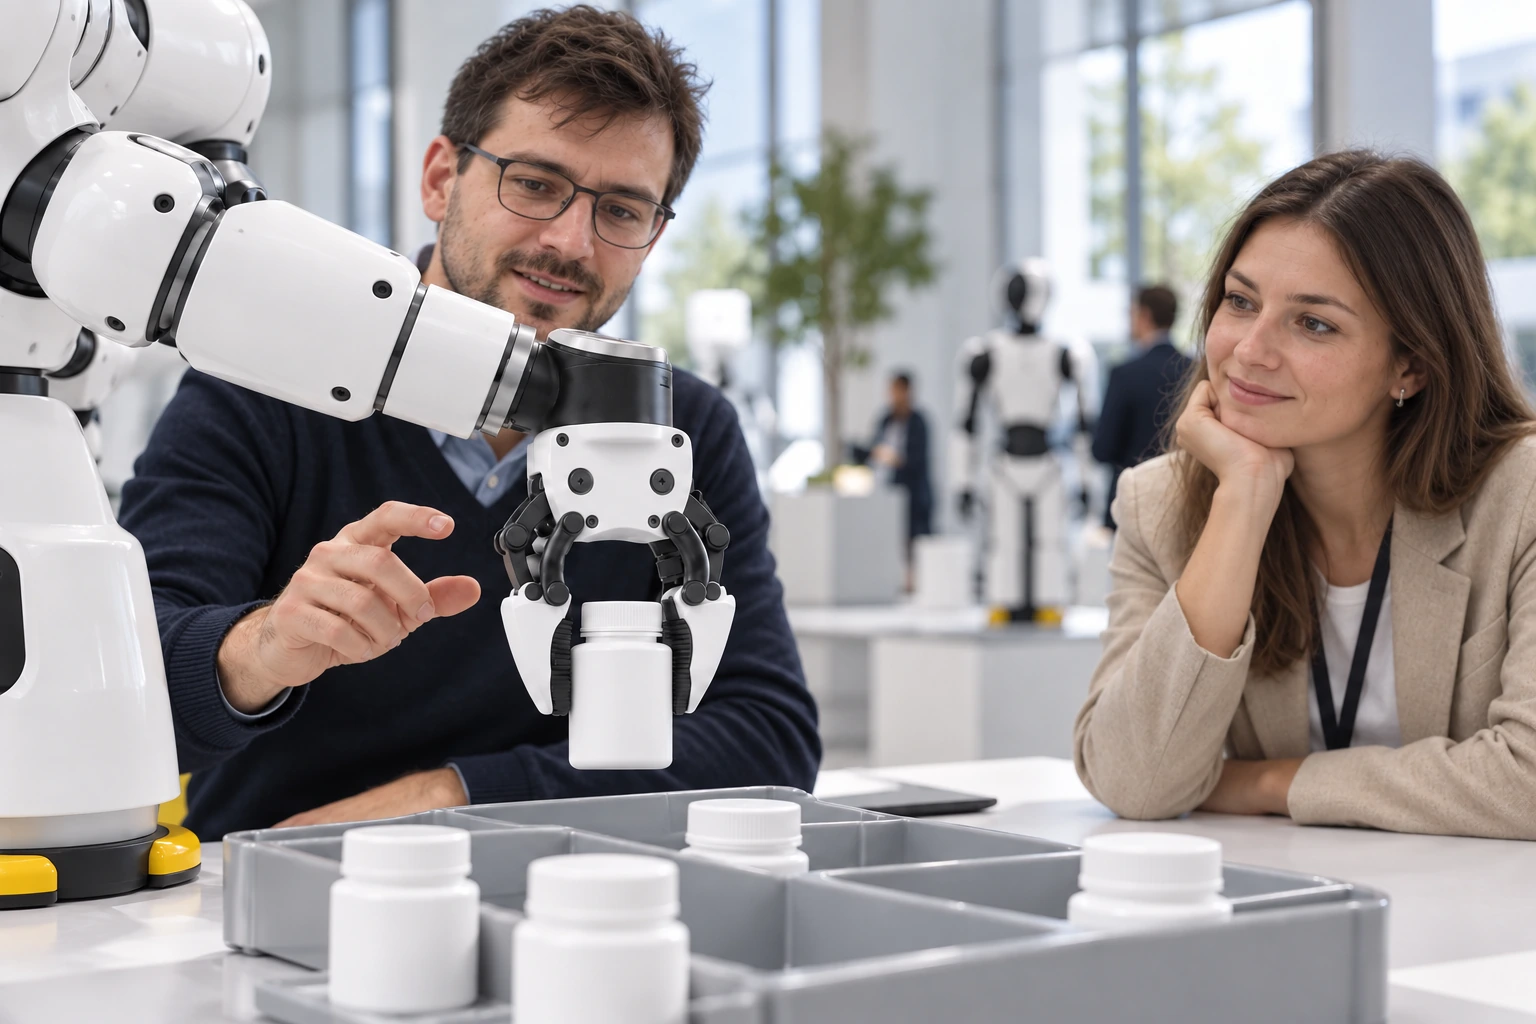
Gestures and hand movements on a compatible robot platform.
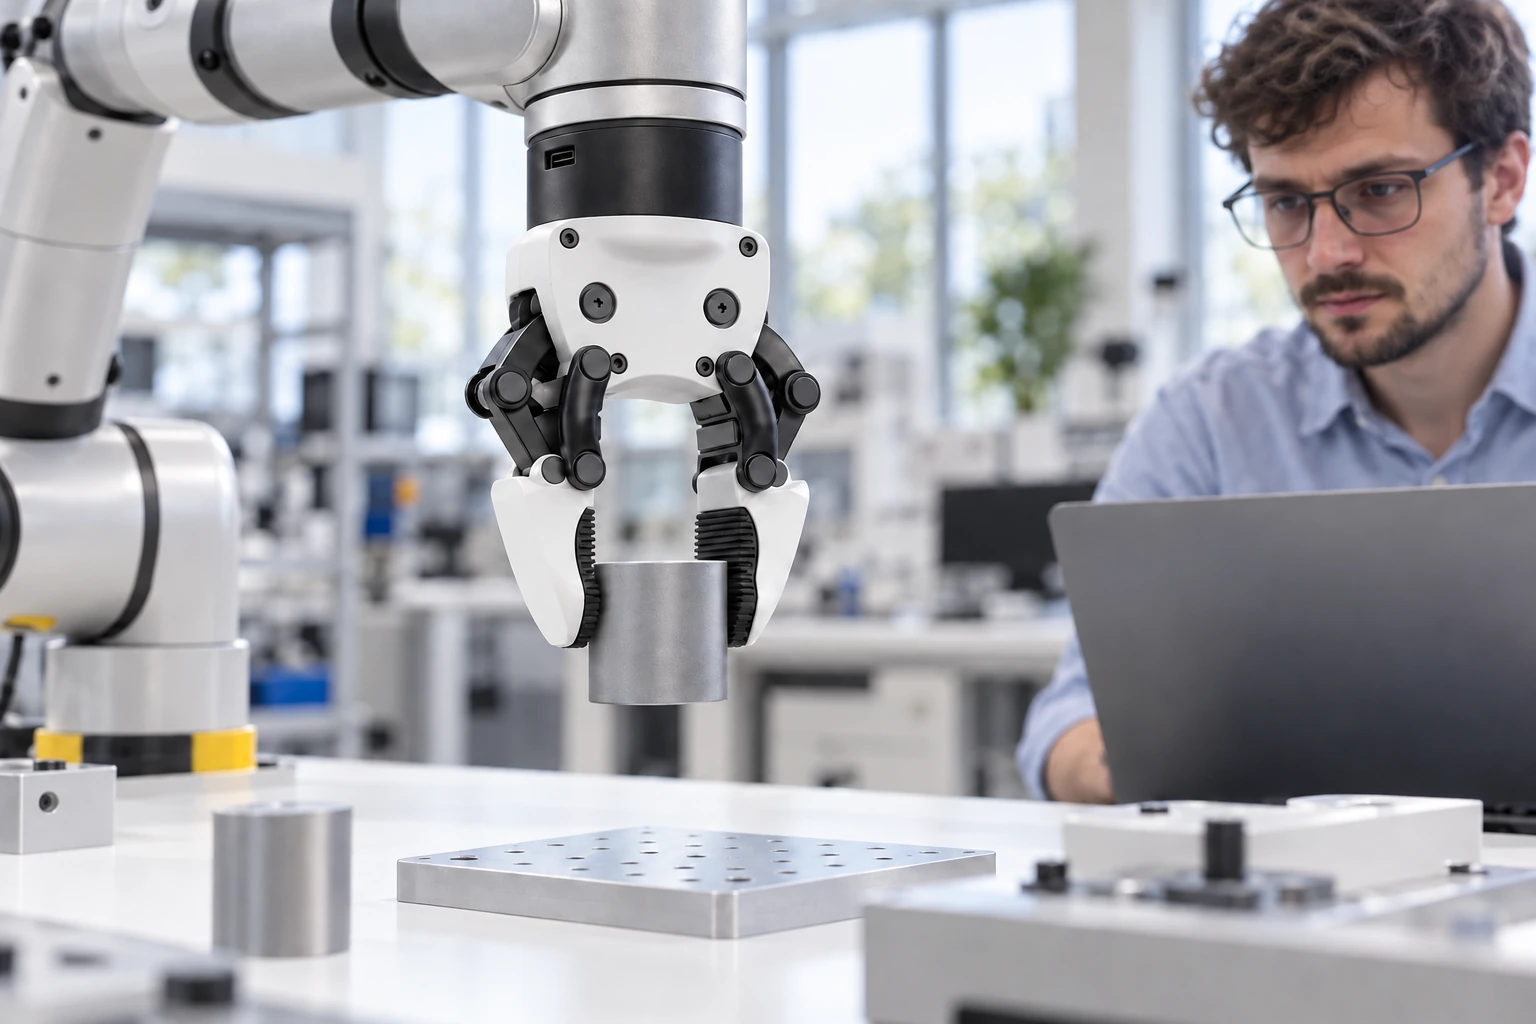
Explore grasping strategies and sensor feedback.

Object handling with a robot arm, suitable adapter and controller.
Mechanical mounting, electrical supply and software control must all be compatible. Check adapters and control integration for the host robot.
No. The usable load depends on the arm, adapter, end effector and the particular grasp together.
Not automatically. Check the exact variant, installed equipment and corresponding specification together.
Product data and manufacturer images: AGIBOT. For custom solution packages, the reference describes the base platform.
We help select the right model, equipment and services.
